PROBLEM
STATEMENT
When you map the seabed with multibeam sonar, LiDAR or satellites, you almost never get a complete picture. Survey boats leave strips of seafloor uncovered between passes, water clarity and clouds block laser scans, and sensors occasionally drop measurements. The result is a bathymetry map full of holes, known in mapping as voids. Reconstructing them with AI, known as bathymetry void filling, is what this project was about.
For StrikeLines, voids meant gaps in the charts their customers rely on to find reefs, ledges and hardbottom. Filling them by hand is slow, and simple interpolation smears the detail that makes a seafloor chart useful. They needed a way to reconstruct what was most likely there, using the clues in the surrounding terrain.
Challenges
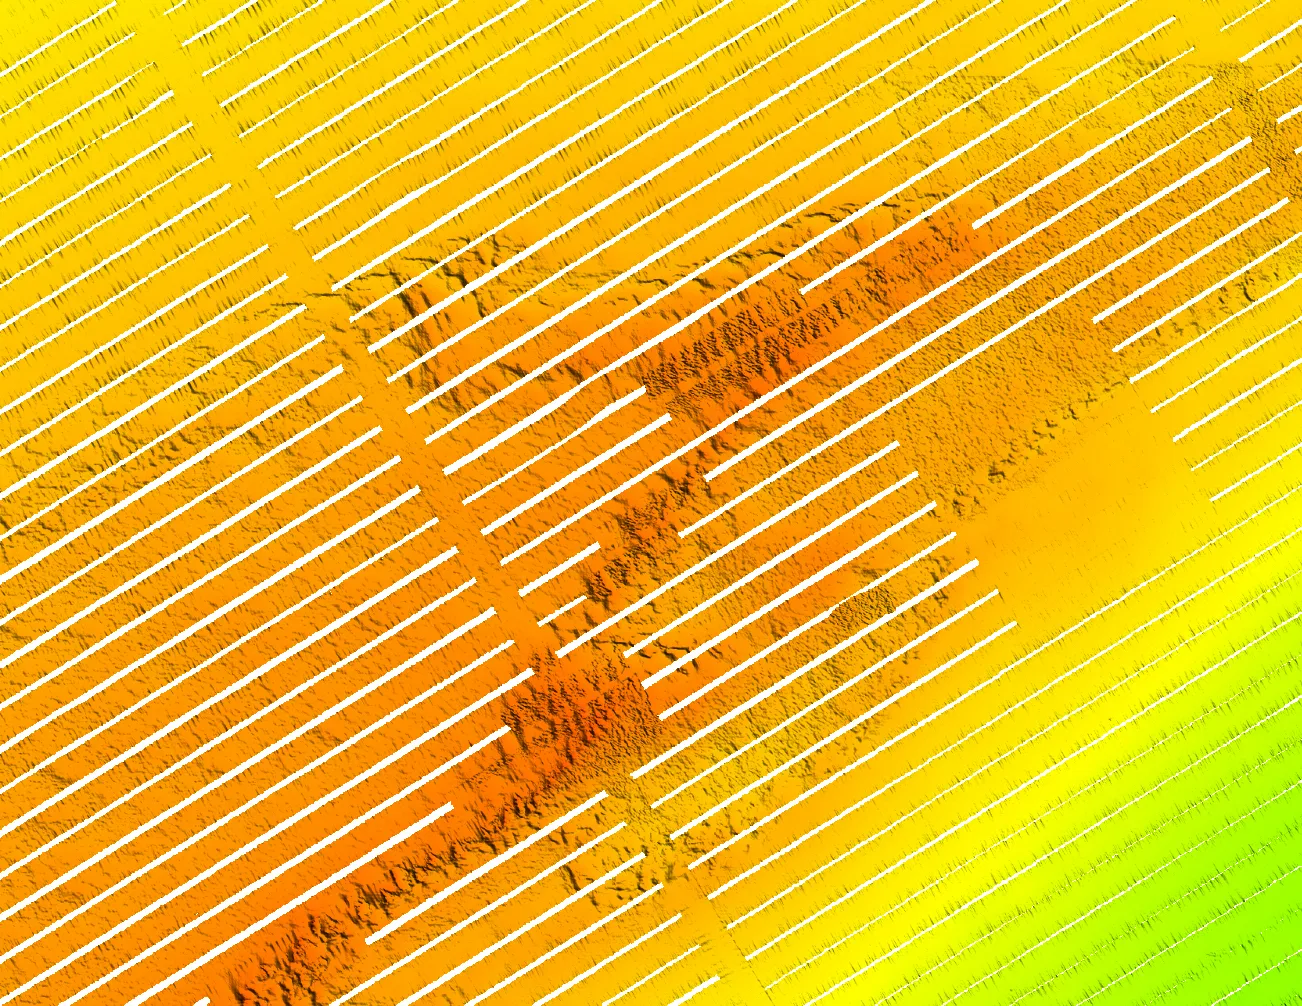
A pretrained model for filling holes in elevation data already existed, but it could not be used as-is. It had been trained on land surface elevation and on simple rectangular holes. StrikeLines’ data was underwater terrain, with long, narrow, diagonal voids that follow the paths of survey vessels, and their surveys were far larger than the small images the model was designed for. The reconstructed areas also had to blend into the real data without visible edges or seams.
- Land surface elevation
- Square, compact holes
- Small image tiles
- Underwater bathymetry
- Long diagonal gaps between survey passes
- Large georeferenced surveys
Strategy
Rather than training a new model from scratch, we chose to adapt one that already understood terrain. Starting from a pretrained diffusion model saved months of training and large amounts of data, and let us focus the engineering effort on what was actually different: underwater terrain and the real shape of survey gaps.
- Land surface elevation
- Square, compact holes
- Small image tiles
- Underwater bathymetry
- Long diagonal gaps between survey passes
- Large georeferenced surveys
Proposed
Solution
We fine-tuned a pretrained diffusion model for AI bathymetry void filling on StrikeLines’ survey data, teaching it how the seafloor behaves instead of dry land. The solution included:
- Bathymetry fine-tuning: retraining the model on underwater elevation data so its reconstructions match seabed features like ridges, ledges and scattered hardbottom.
- Custom masks: training masks that mimic the client’s real void patterns, such as the stripes between sonar passes, instead of generic square holes.
- Tiled processing: splitting large GeoTIFF surveys into tiles, reconstructing each one and stitching them back together with the original georeferencing intact.
- Overlapping tiles and seam smoothing: averaging overlapping predictions and smoothing tile boundaries so the filled areas blend in without visible seams.

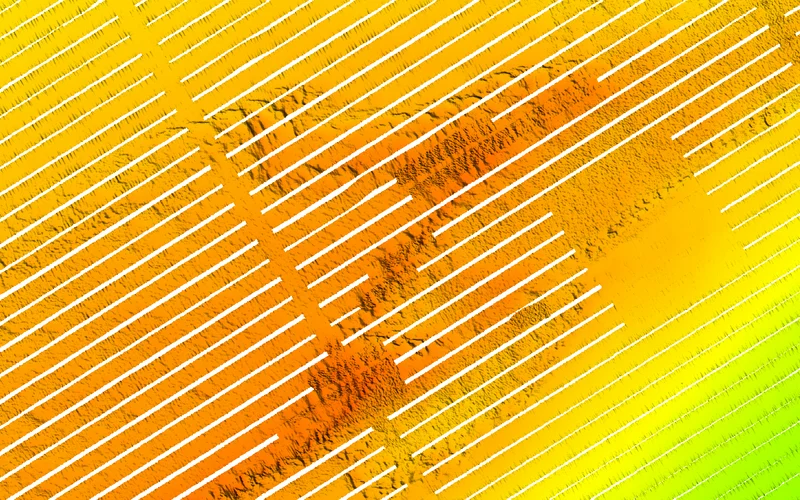
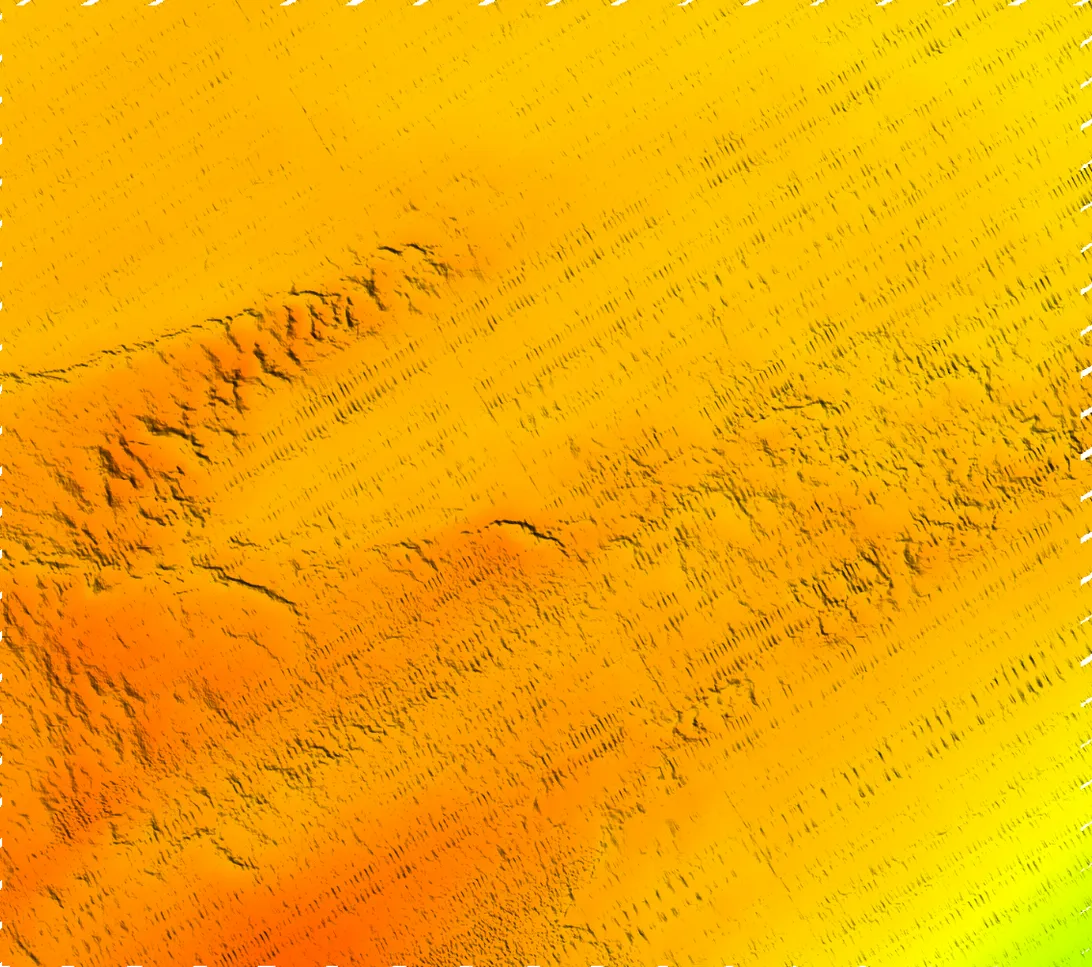
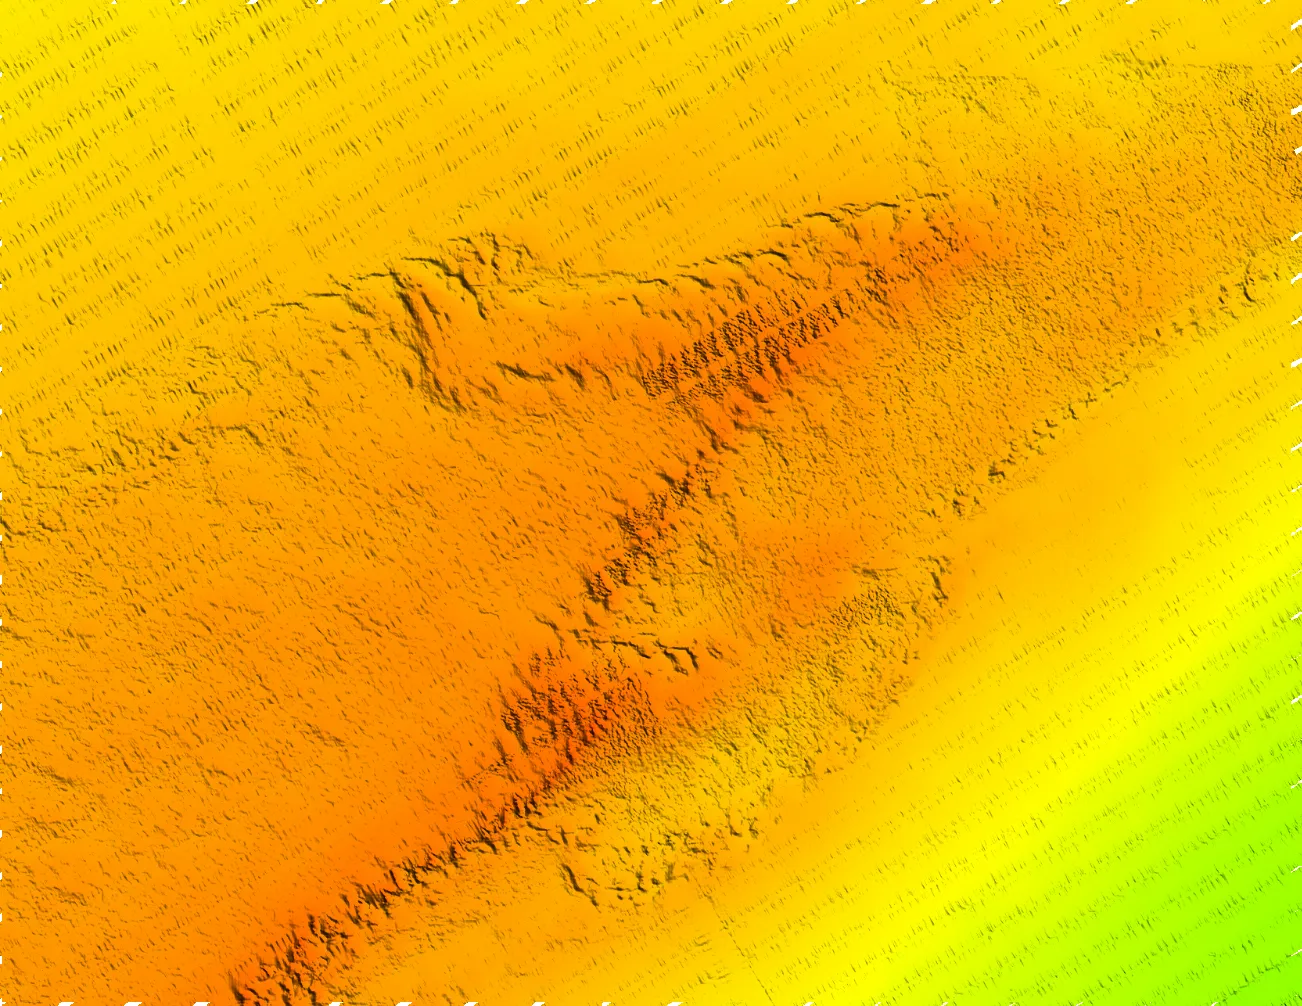
Drag the handle to compare. Left: survey data with voids between sonar passes. Right: the same area after AI reconstruction.
Project Stages
Data & Gap Analysis
We reviewed StrikeLines’ bathymetry surveys to understand their resolution, depth ranges and, above all, the shape of their voids. Most gaps were long diagonal stripes left between survey passes, very different from the holes the original model had seen.
Model Adaptation
We started from a published diffusion model for elevation void filling (Diff-DEM, built on the Palette image-to-image framework) and prepared it for underwater terrain, including per-tile normalisation based only on valid depth values.
Fine-Tuning
We fine-tuned the model on the client’s bathymetry using custom masks that reproduce their real void patterns, so it learned to continue ridges and seabed features across gaps instead of smoothing them away.
Large-Scale Processing
We built a tiled pipeline that processes full GeoTIFF surveys: it splits them into tiles, runs the model with overlap, averages overlapping predictions, smooths tile boundaries and writes the result back as a georeferenced file ready for charting.
AI Bathymetry Void Filling Results

A seabed ridge crossed by survey gaps. The model continues the ridge and its texture through each missing stripe.
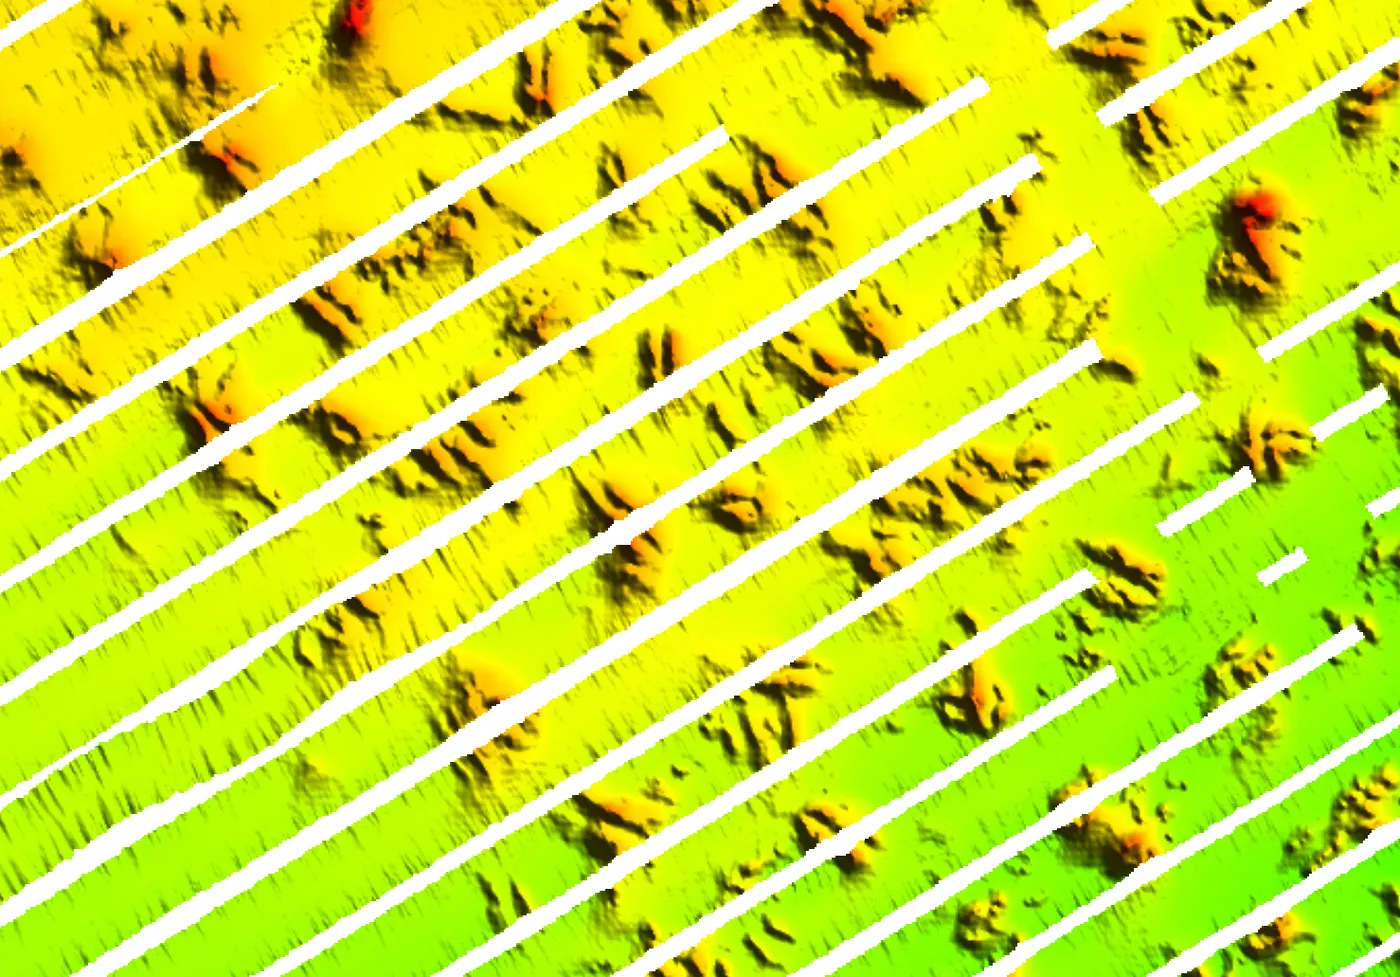
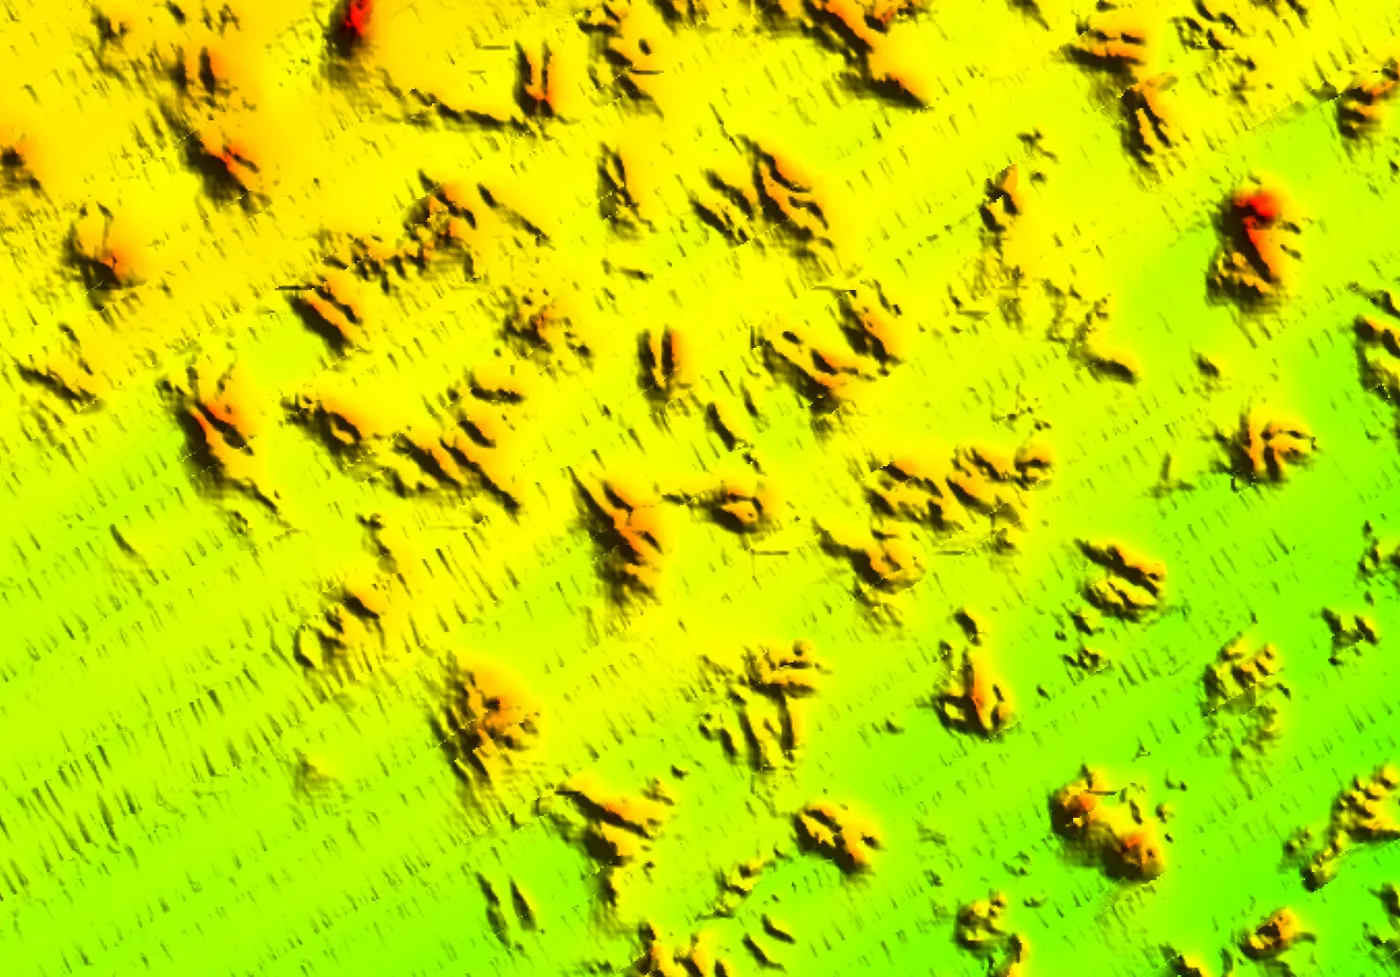
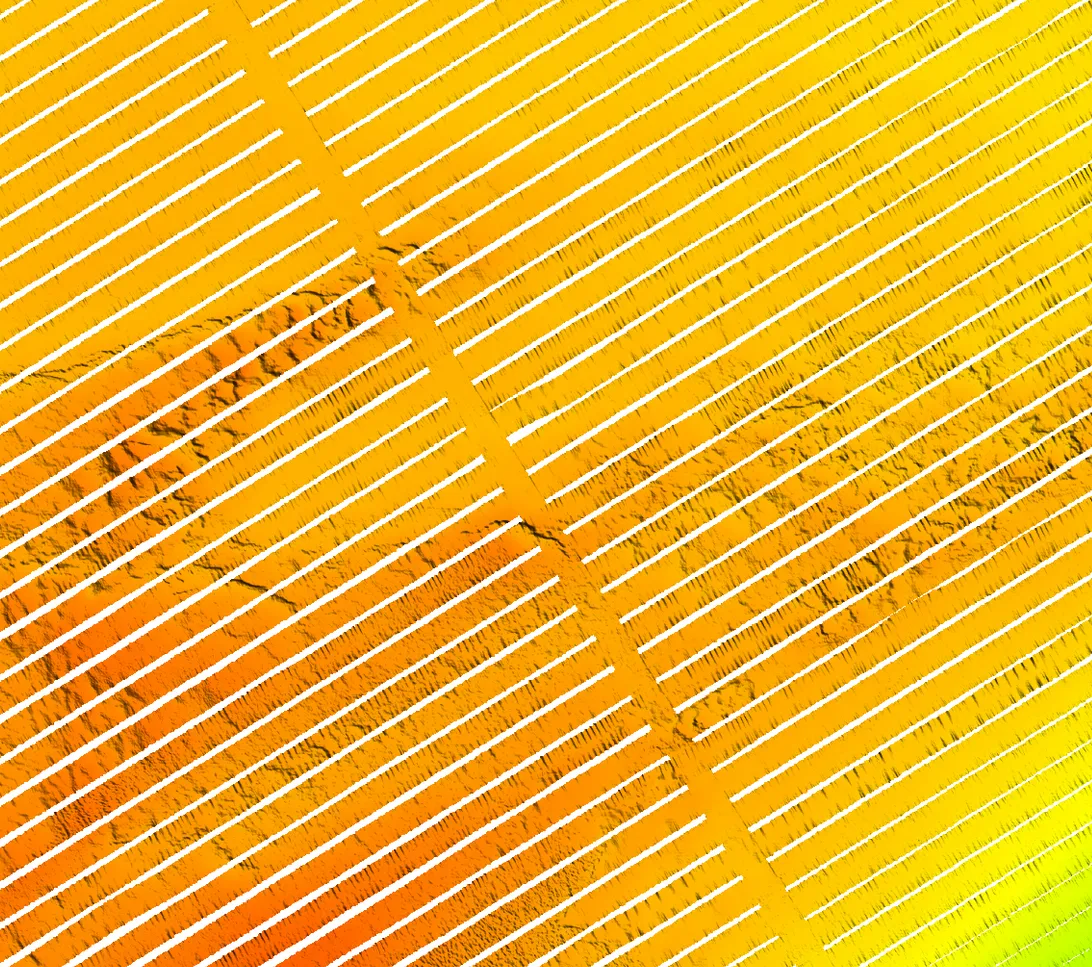
Scattered hardbottom features. Every missing band is filled, with features that follow the patterns around them.
This is GeoAI in practice: applying AI to spatial data to solve a real mapping problem. Explore more of our work in our case studies and portfolio.
FAQ
What is bathymetry?
Bathymetry is the measurement and mapping of underwater depth, the underwater equivalent of a topographic map. It is usually collected with multibeam or single-beam sonar, airborne LiDAR or satellite-derived methods, and stored as a grid of depth values called a digital bathymetric model.
What are voids in bathymetric data?
Voids are areas of a bathymetry map with no depth measurements. They appear as gaps between survey passes, in shadows behind seabed features, where water clarity or cloud cover blocks laser surveys, or where sensors drop readings.
How does AI fill gaps in seafloor maps?
A diffusion model looks at the valid terrain around each gap and generates a plausible continuation of the seafloor. Because it is trained on real terrain, it reproduces features such as ridges and ledges instead of the flat, blurred surfaces produced by simple interpolation.
Is AI-filled bathymetry accurate enough to use?
AI-reconstructed areas are well suited to visual charts, planning and filling small gaps where re-surveying is impractical. They are estimates, not measurements, so reconstructed areas should stay flagged and should not be used for navigation safety without verification.
Can this work with other geospatial data?
Yes. The same approach applies to land elevation models, LiDAR, satellite-derived depth and other raster data, as long as the model is adapted to the data type and to the shape of its missing areas.